


Zihao Zhang, Haochen Tian, Tianyu Li, Changhui Jing, Jingliang He, Naisheng Ye, Ziyuan Pu, Zhenjie Yang
- 📧 Primary Contact: Zihao Zhang (zihao.zhang@opendrivelab.com)
- 🖊️ Joint effort by SEU, OpenDriveLab at HKU, and SLAI.
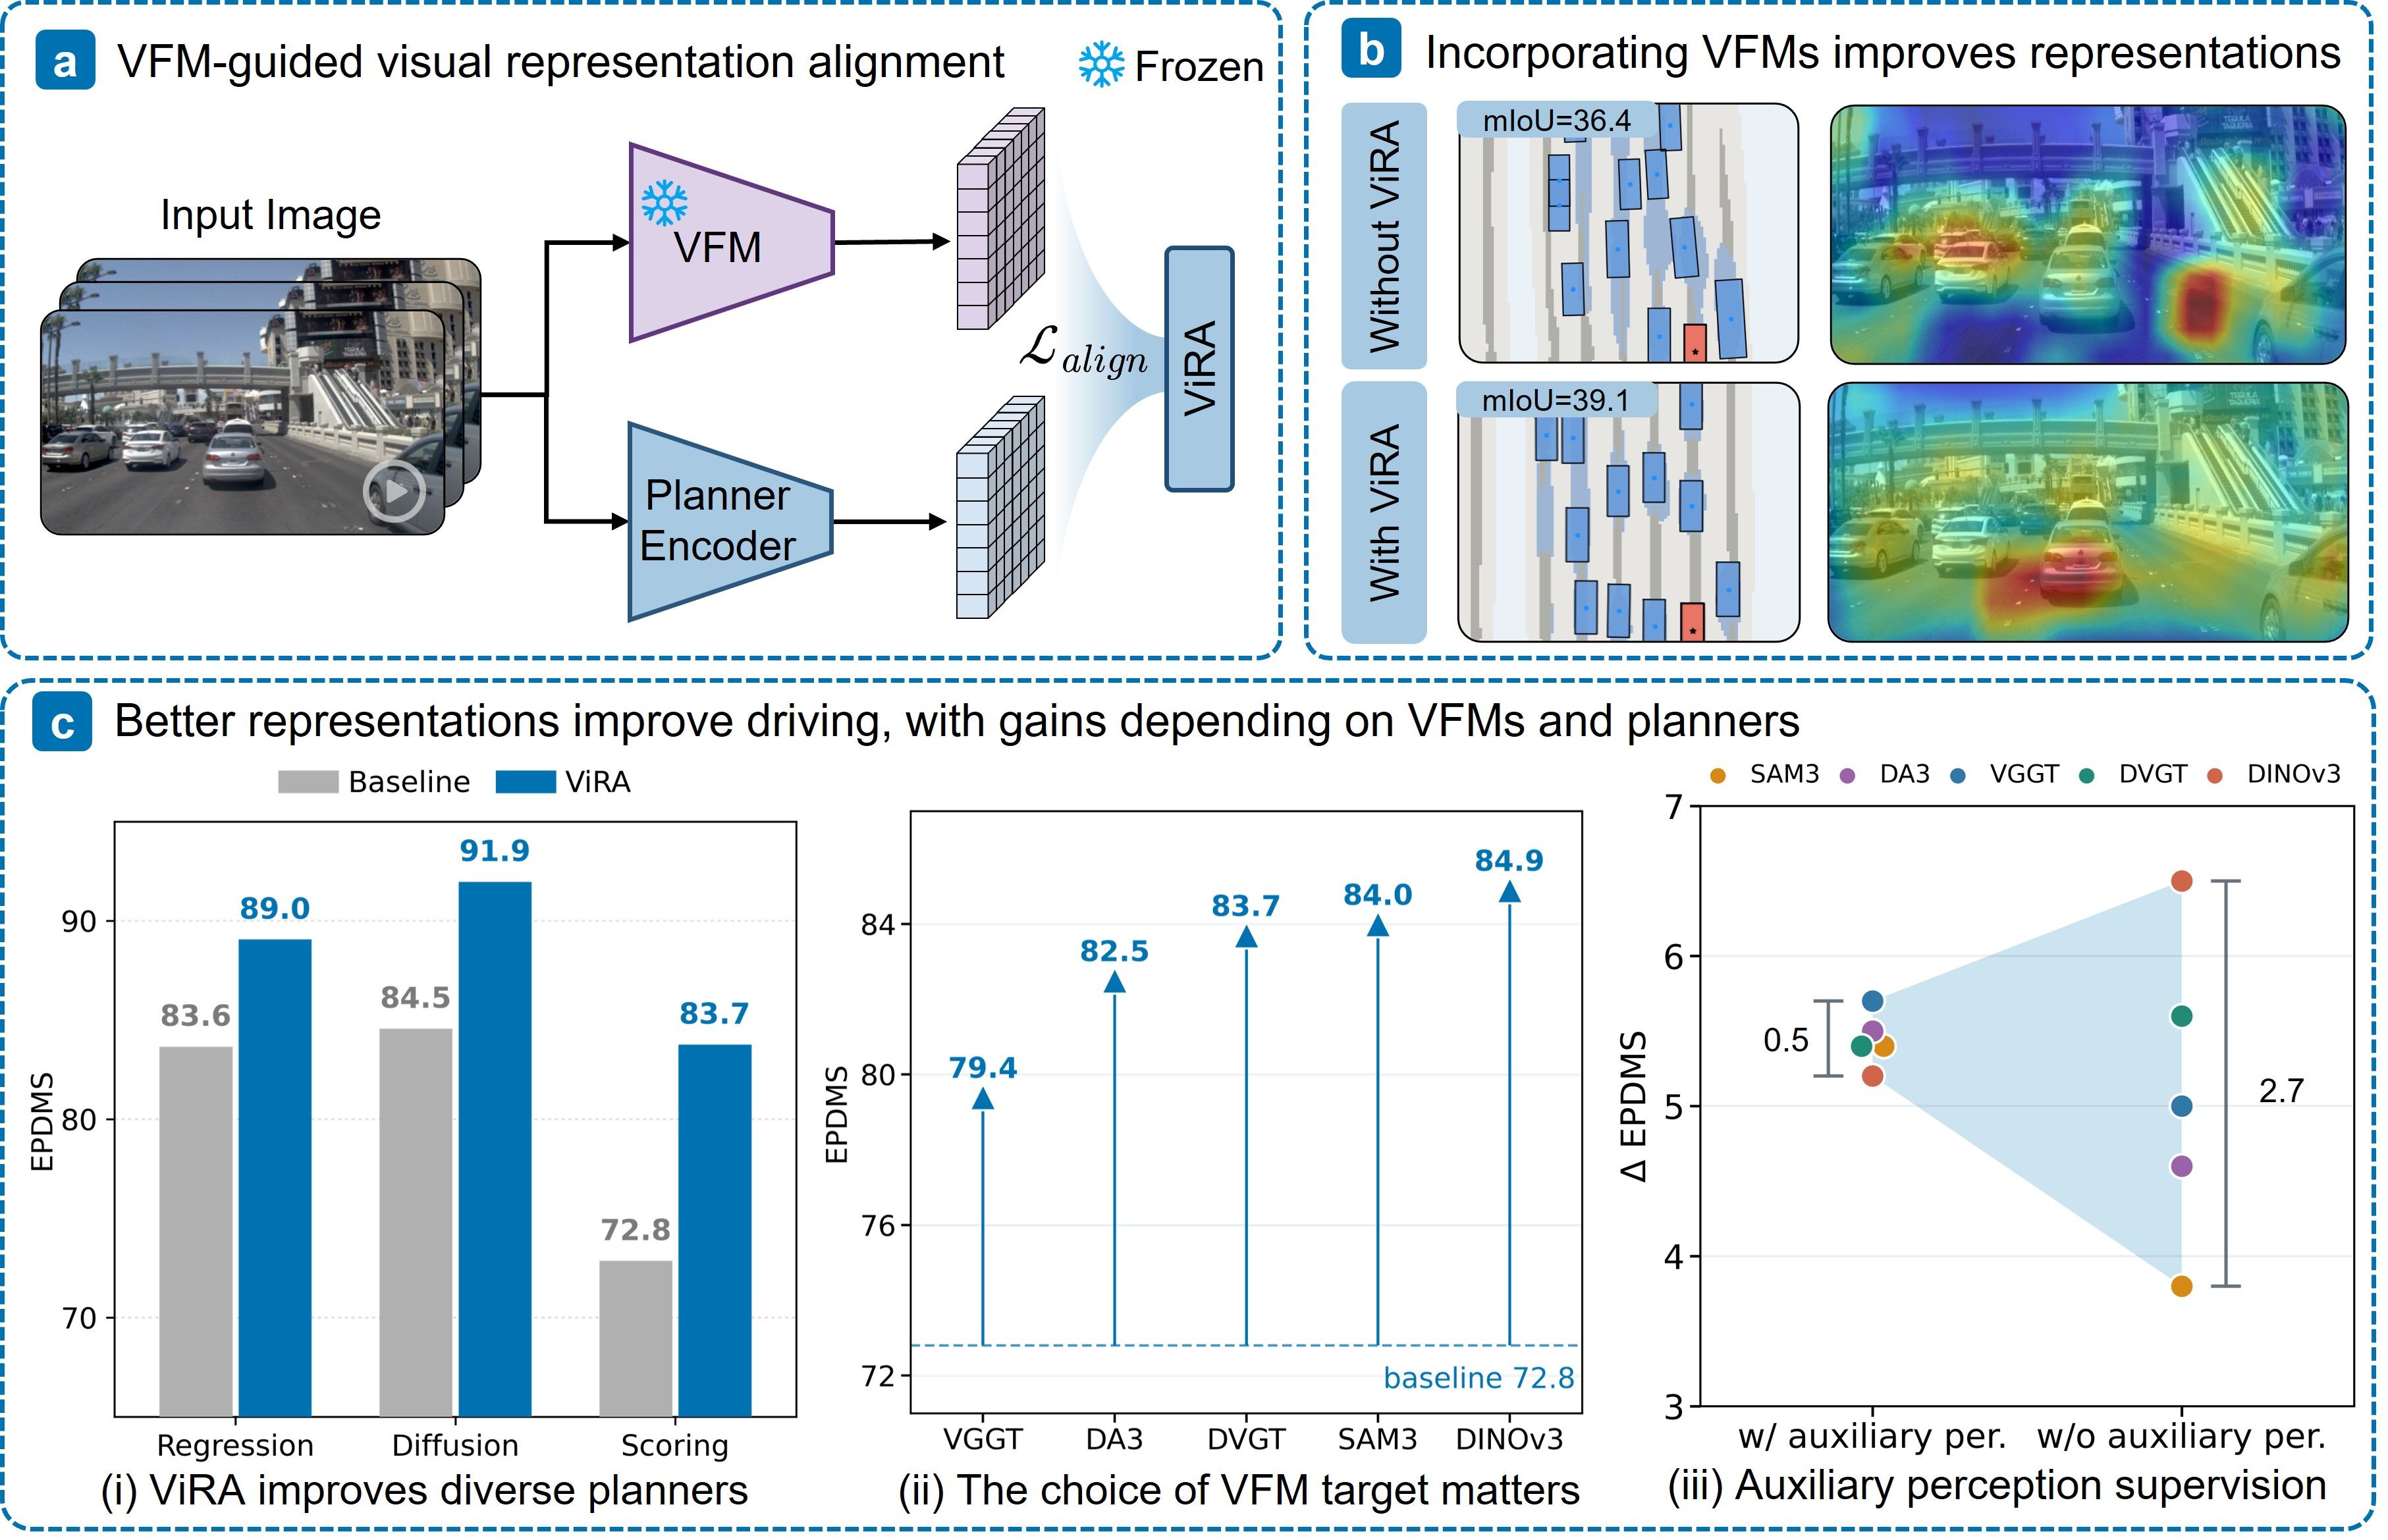
- 🚗 Planner-agnostic alignment: ViRA improves driving across diverse end-to-end planners without changing their deployed architecture or inference cost.
- 🔍 Target selection and supervision matter: VFM target choice affects planning gains, while auxiliary perception supervision narrows performance differences across targets.
- 📈 ViRA-Diffusion: DINOv3 alignment enables 92.3 EPDMS on NAVSIM v2 navtest without auxiliary perception supervision.
[2026/10/7]We released our paper on arXiv.
- Results and Demo release.
- Code release.
- Checkpoints release.
Camera-only. Rap* is our reimplementation with a different backbone and without the original data augmentation. HUGSIM is zero-shot: planners are trained only on NAVSIM.
| Method | Decoder | NAVSIM v2 navtest | NAVSIM v2 navhard | HUGSIM |
|---|---|---|---|---|
| EPDMS | EPDMS | HD-Score | ||
| Perception-based | ||||
| TransFuser | Regression | 83.6 | 27.6 | 22.1 |
| TransFuser-ViRA | 89.0 | +5.4 | 31.7 | +4.1 | 24.8 | +2.7 | |
| DiffusionDrive | Diffusion | 84.5 | 30.5 | 22.2 |
| DiffusionDrive-ViRA | 91.9 | +7.4 | 35.8 | +5.3 | 28.6 | +6.4 | |
| Perception-free | ||||
| Rap* | Scoring | 72.8 | 32.8 | 7.3 |
| Rap*-ViRA | 83.7 | +10.9 | 49.2 | +16.4 | 10.3 | +3.0 | |
ViRA-Diffusion is DiffusionDrive trained with DINOv3 alignment and without auxiliary perception supervision.
| Method | NAVSIM v2 navtest EPDMS |
|---|---|
| Epona | 85.1 |
| DiffusionDriveV2 | 87.5 |
| Latent-WAM | 89.3 |
| DriveFuture | 89.9 |
| SparseDriveV2 | 90.1 |
| Discrete-WAM | 90.4 |
| ViRA-Diffusion | 92.3 |
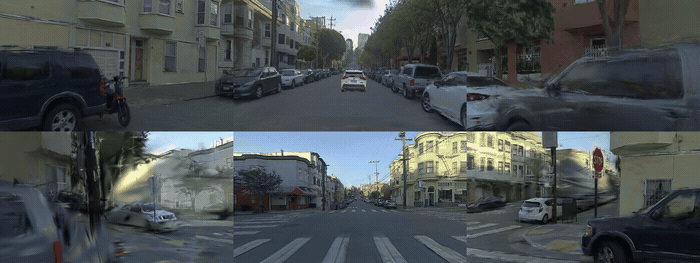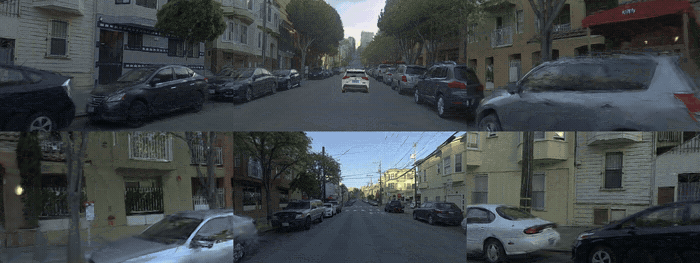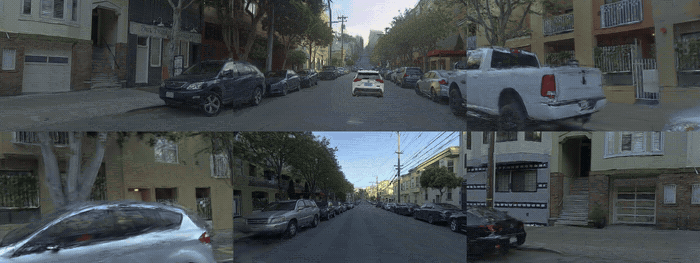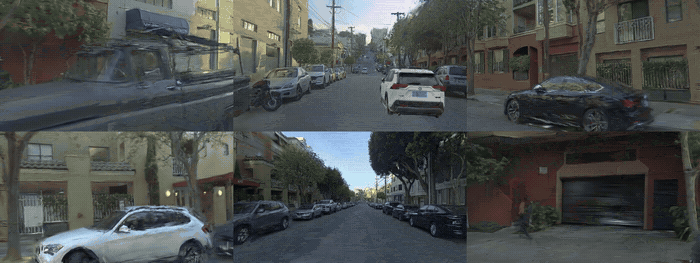
(a) Car following: the lead vehicle brakes suddenly
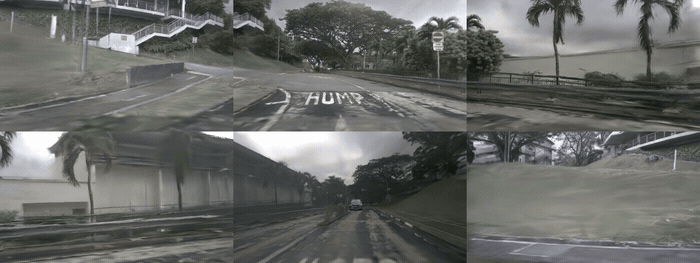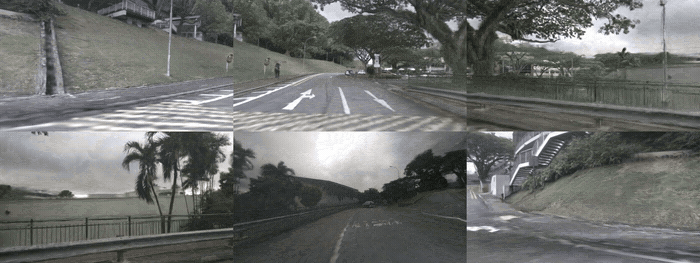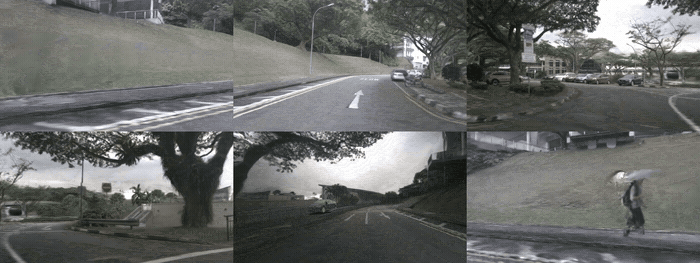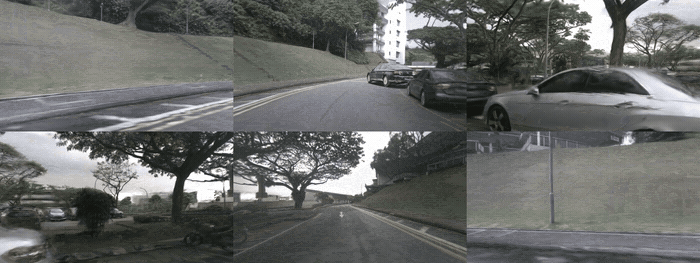
(b) Normal driving: a vehicle crosses in from the sidewalk
We acknowledge all the open-source contributors for the following projects to make this work possible:
All content in this repository is under the Apache-2.0 license.
If any parts of our paper and code help your research, please consider citing us and giving a star to our repository.